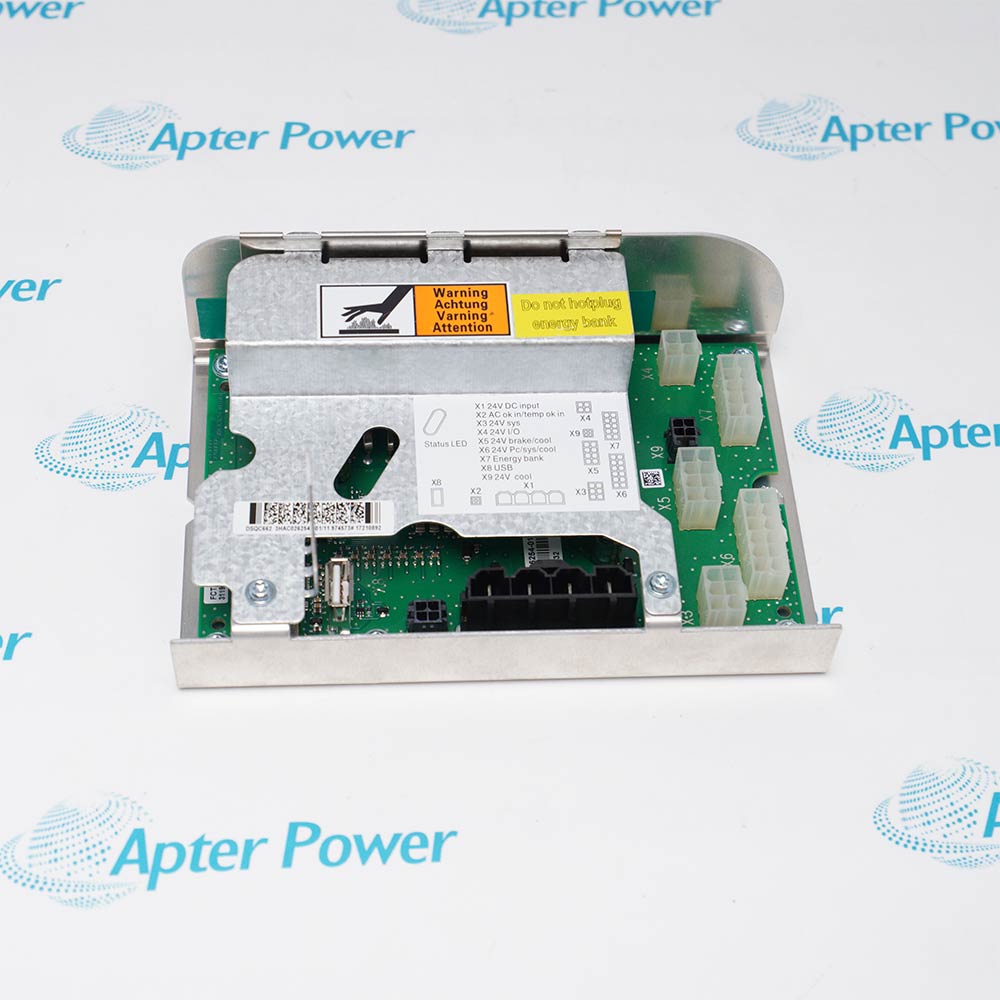
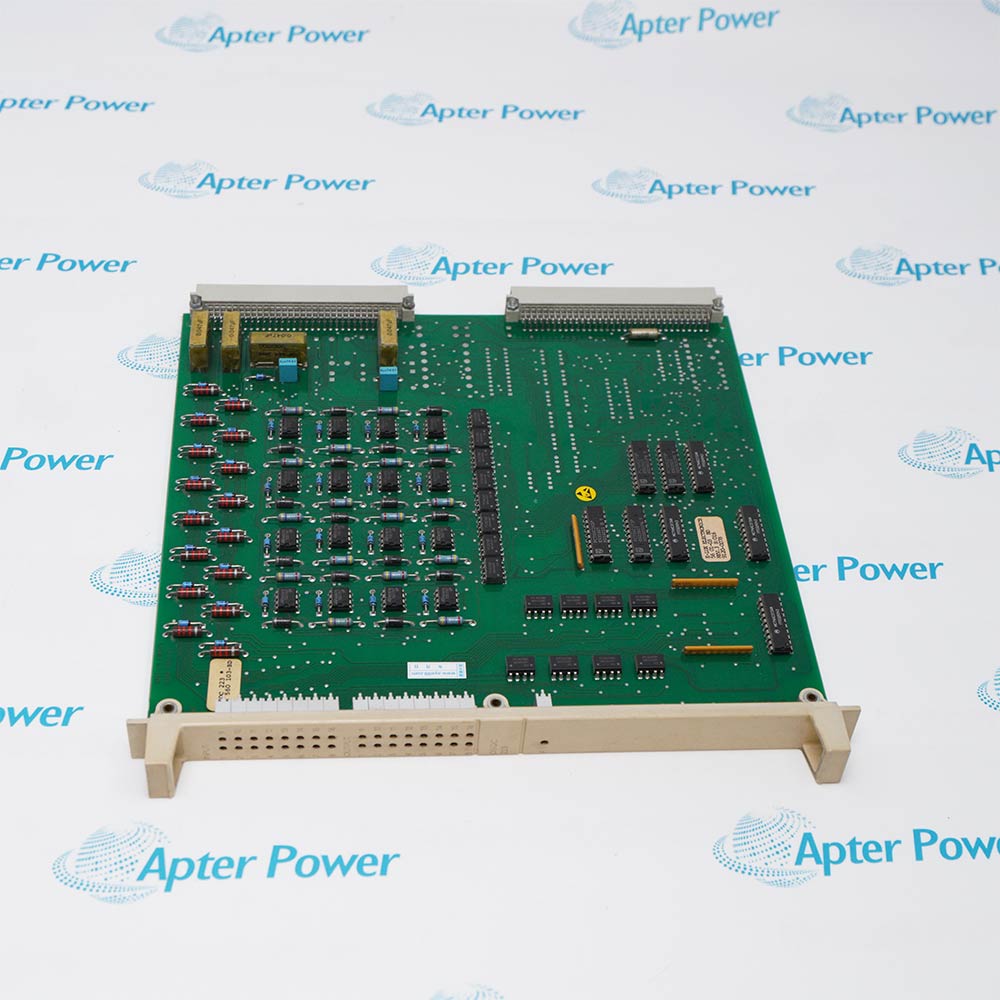
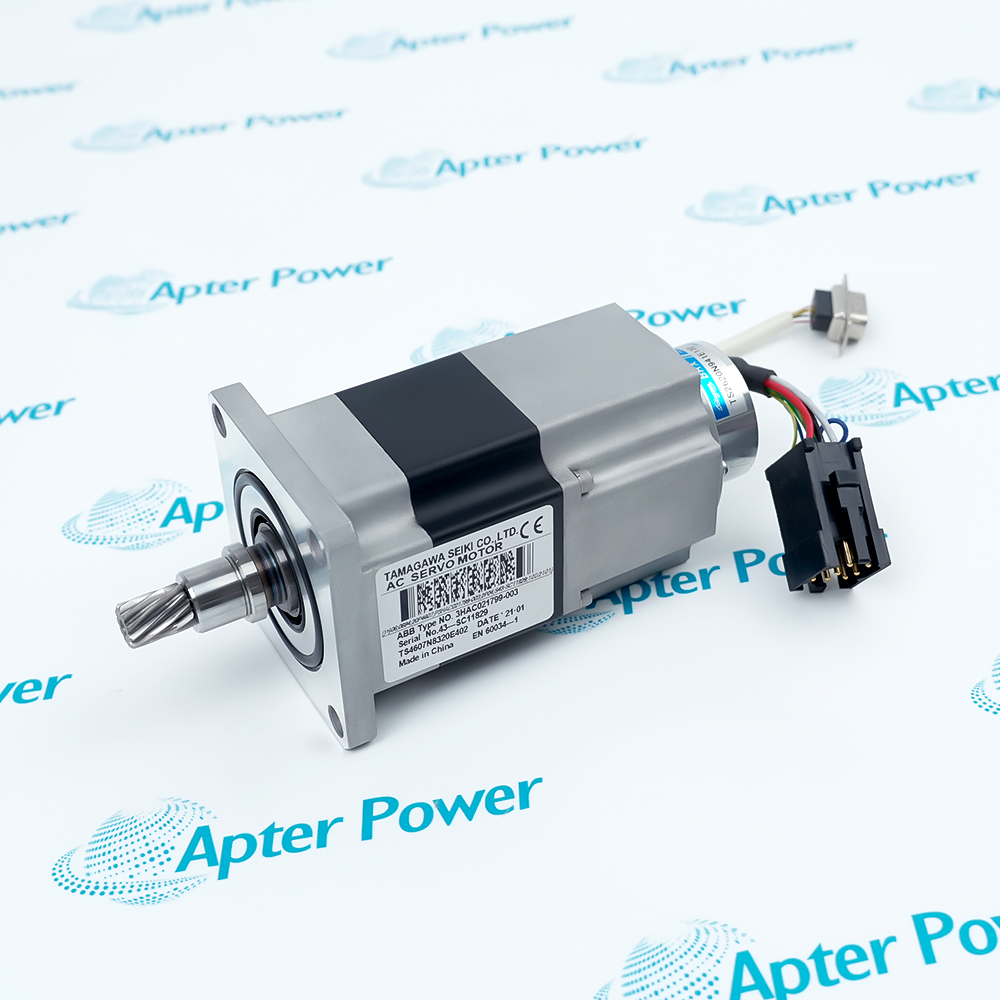
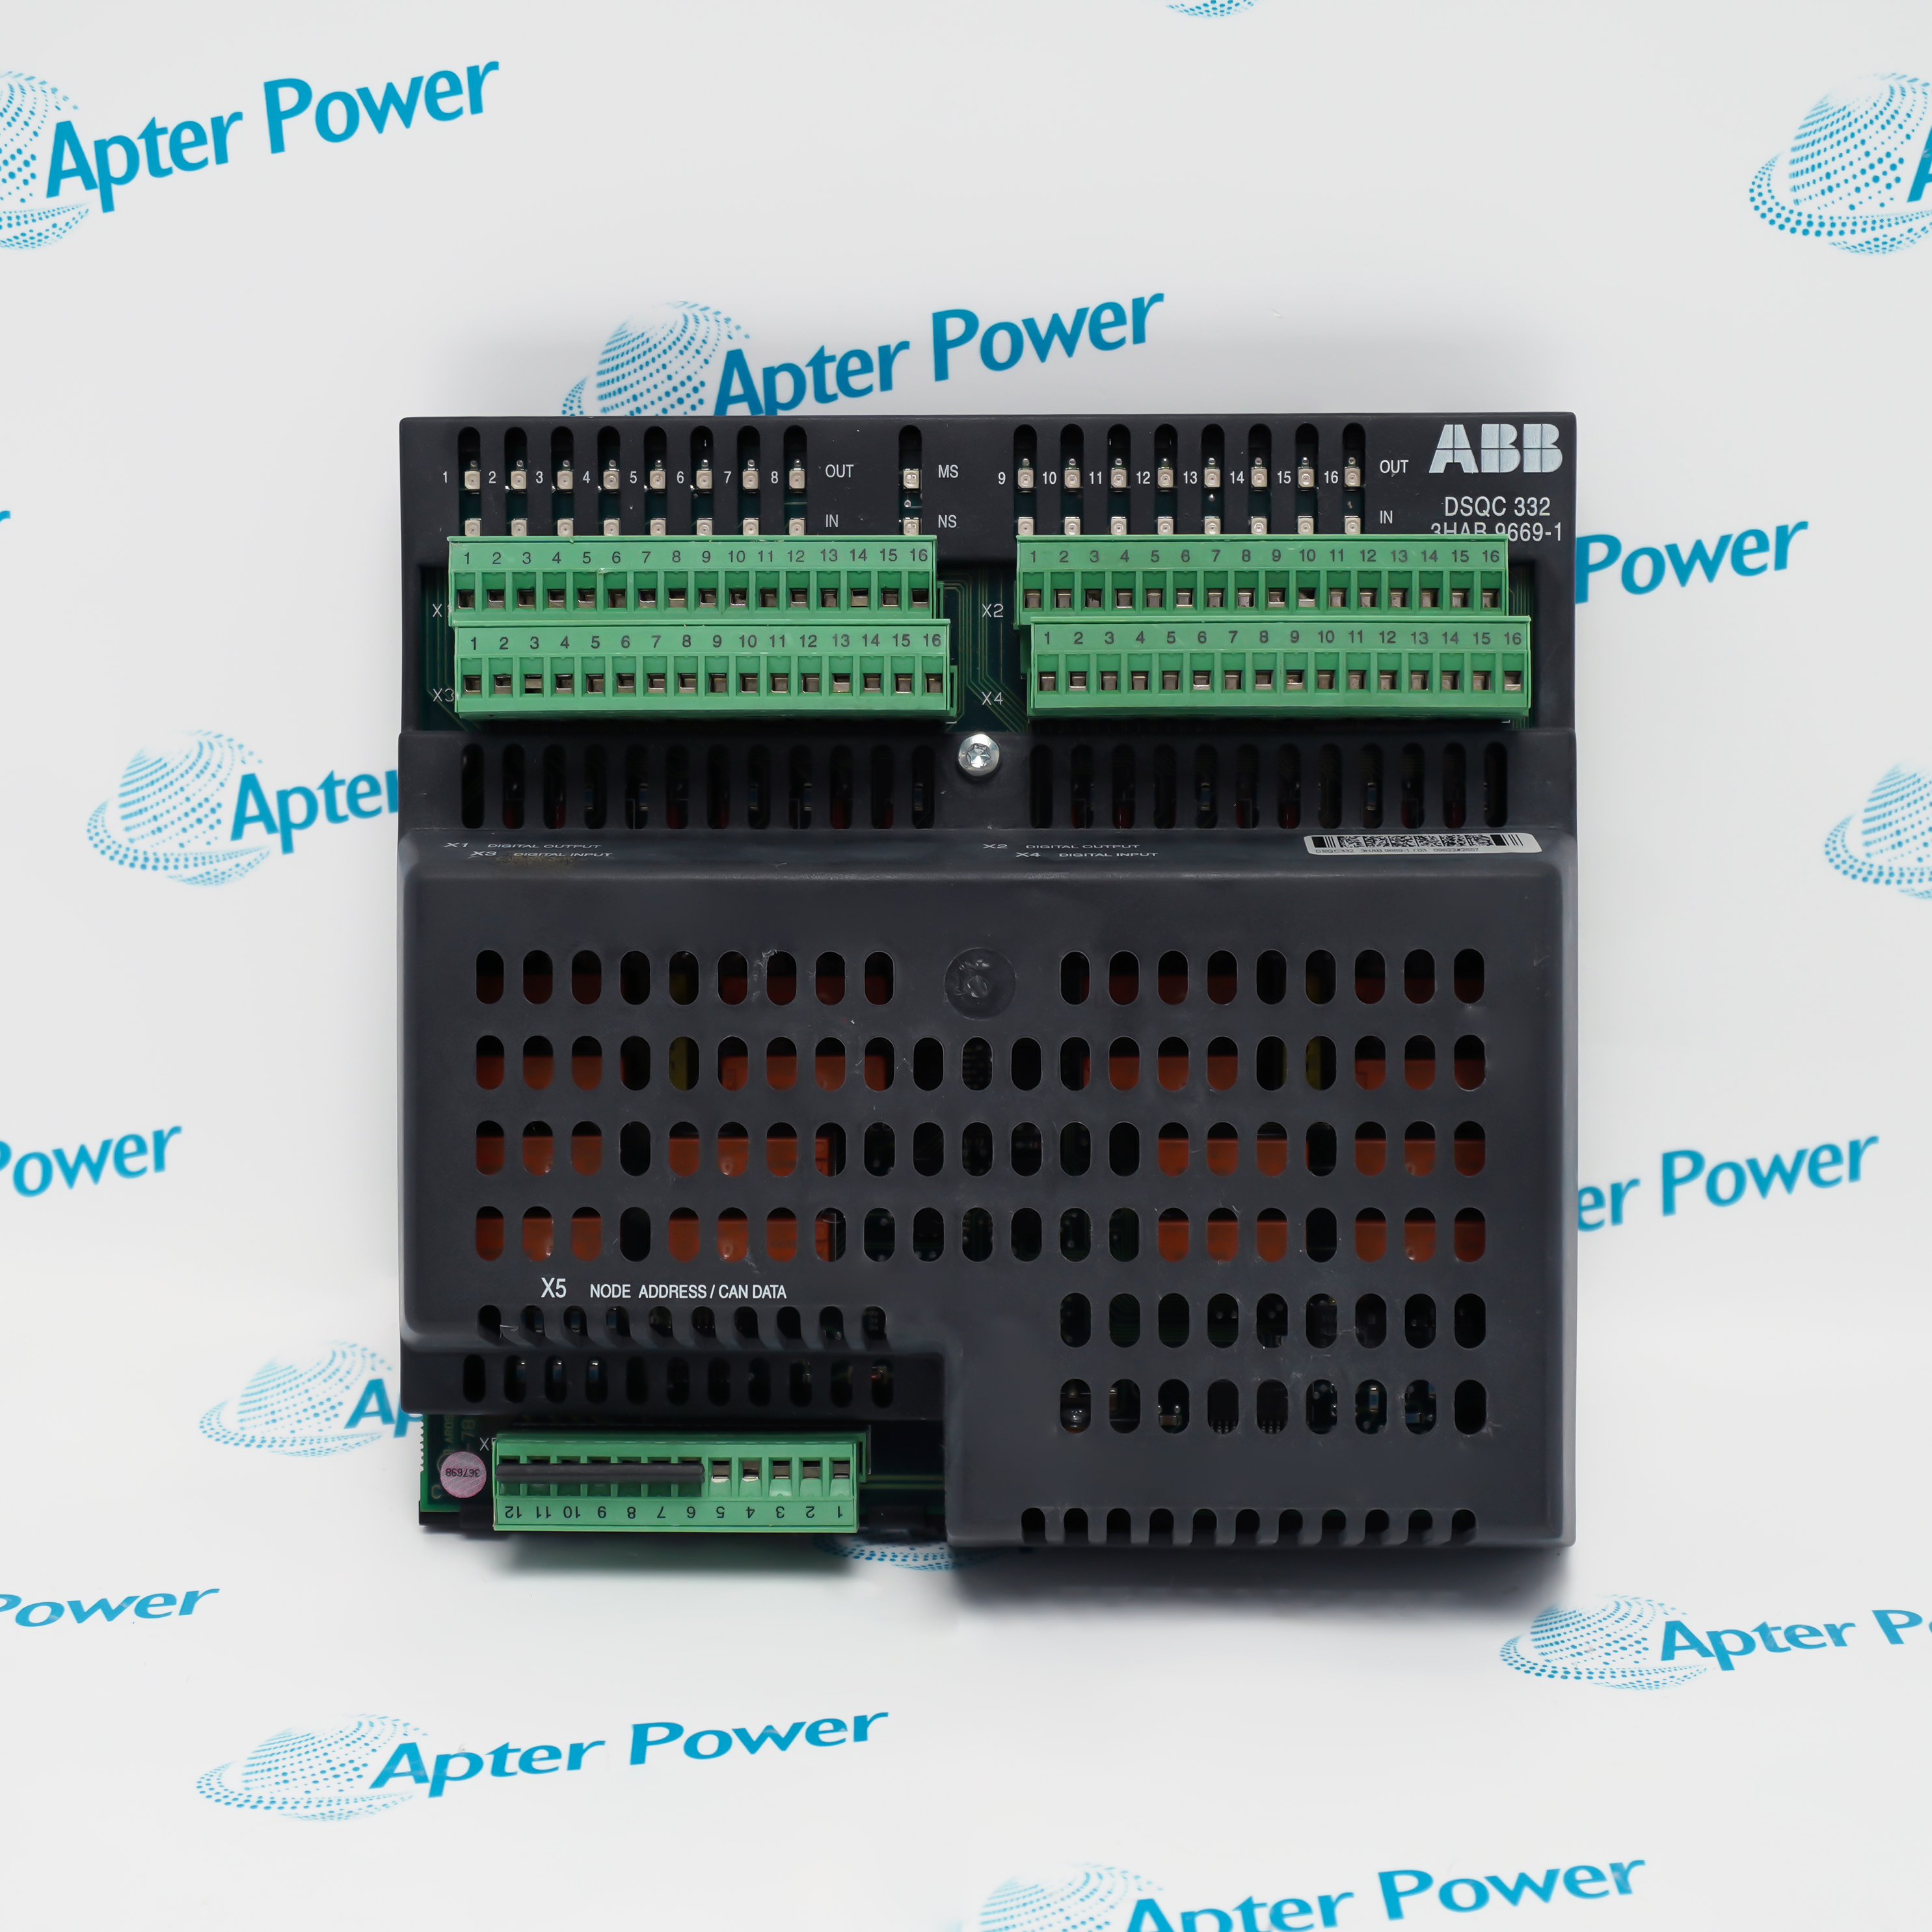
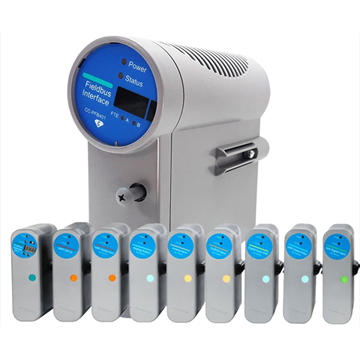

The unit is installed in the robot-controller cabinet with the selected internal or external power arrangement. Commissioning includes channel mapping, terminal and supply verification, controller configuration and controlled interlock tests.
Important Notice: Confirm DSQC332, option 63-1, S4Cplus host, hardware revision, sixteen input and sixteen output assignments, internal or external power selection, terminals, commons, protective grounding, robot configuration and controlled interlock-test results before commissioning.
The first document presents model-specific technical identity and engineering data. The second provides a separate installation, connection and commissioning workflow.
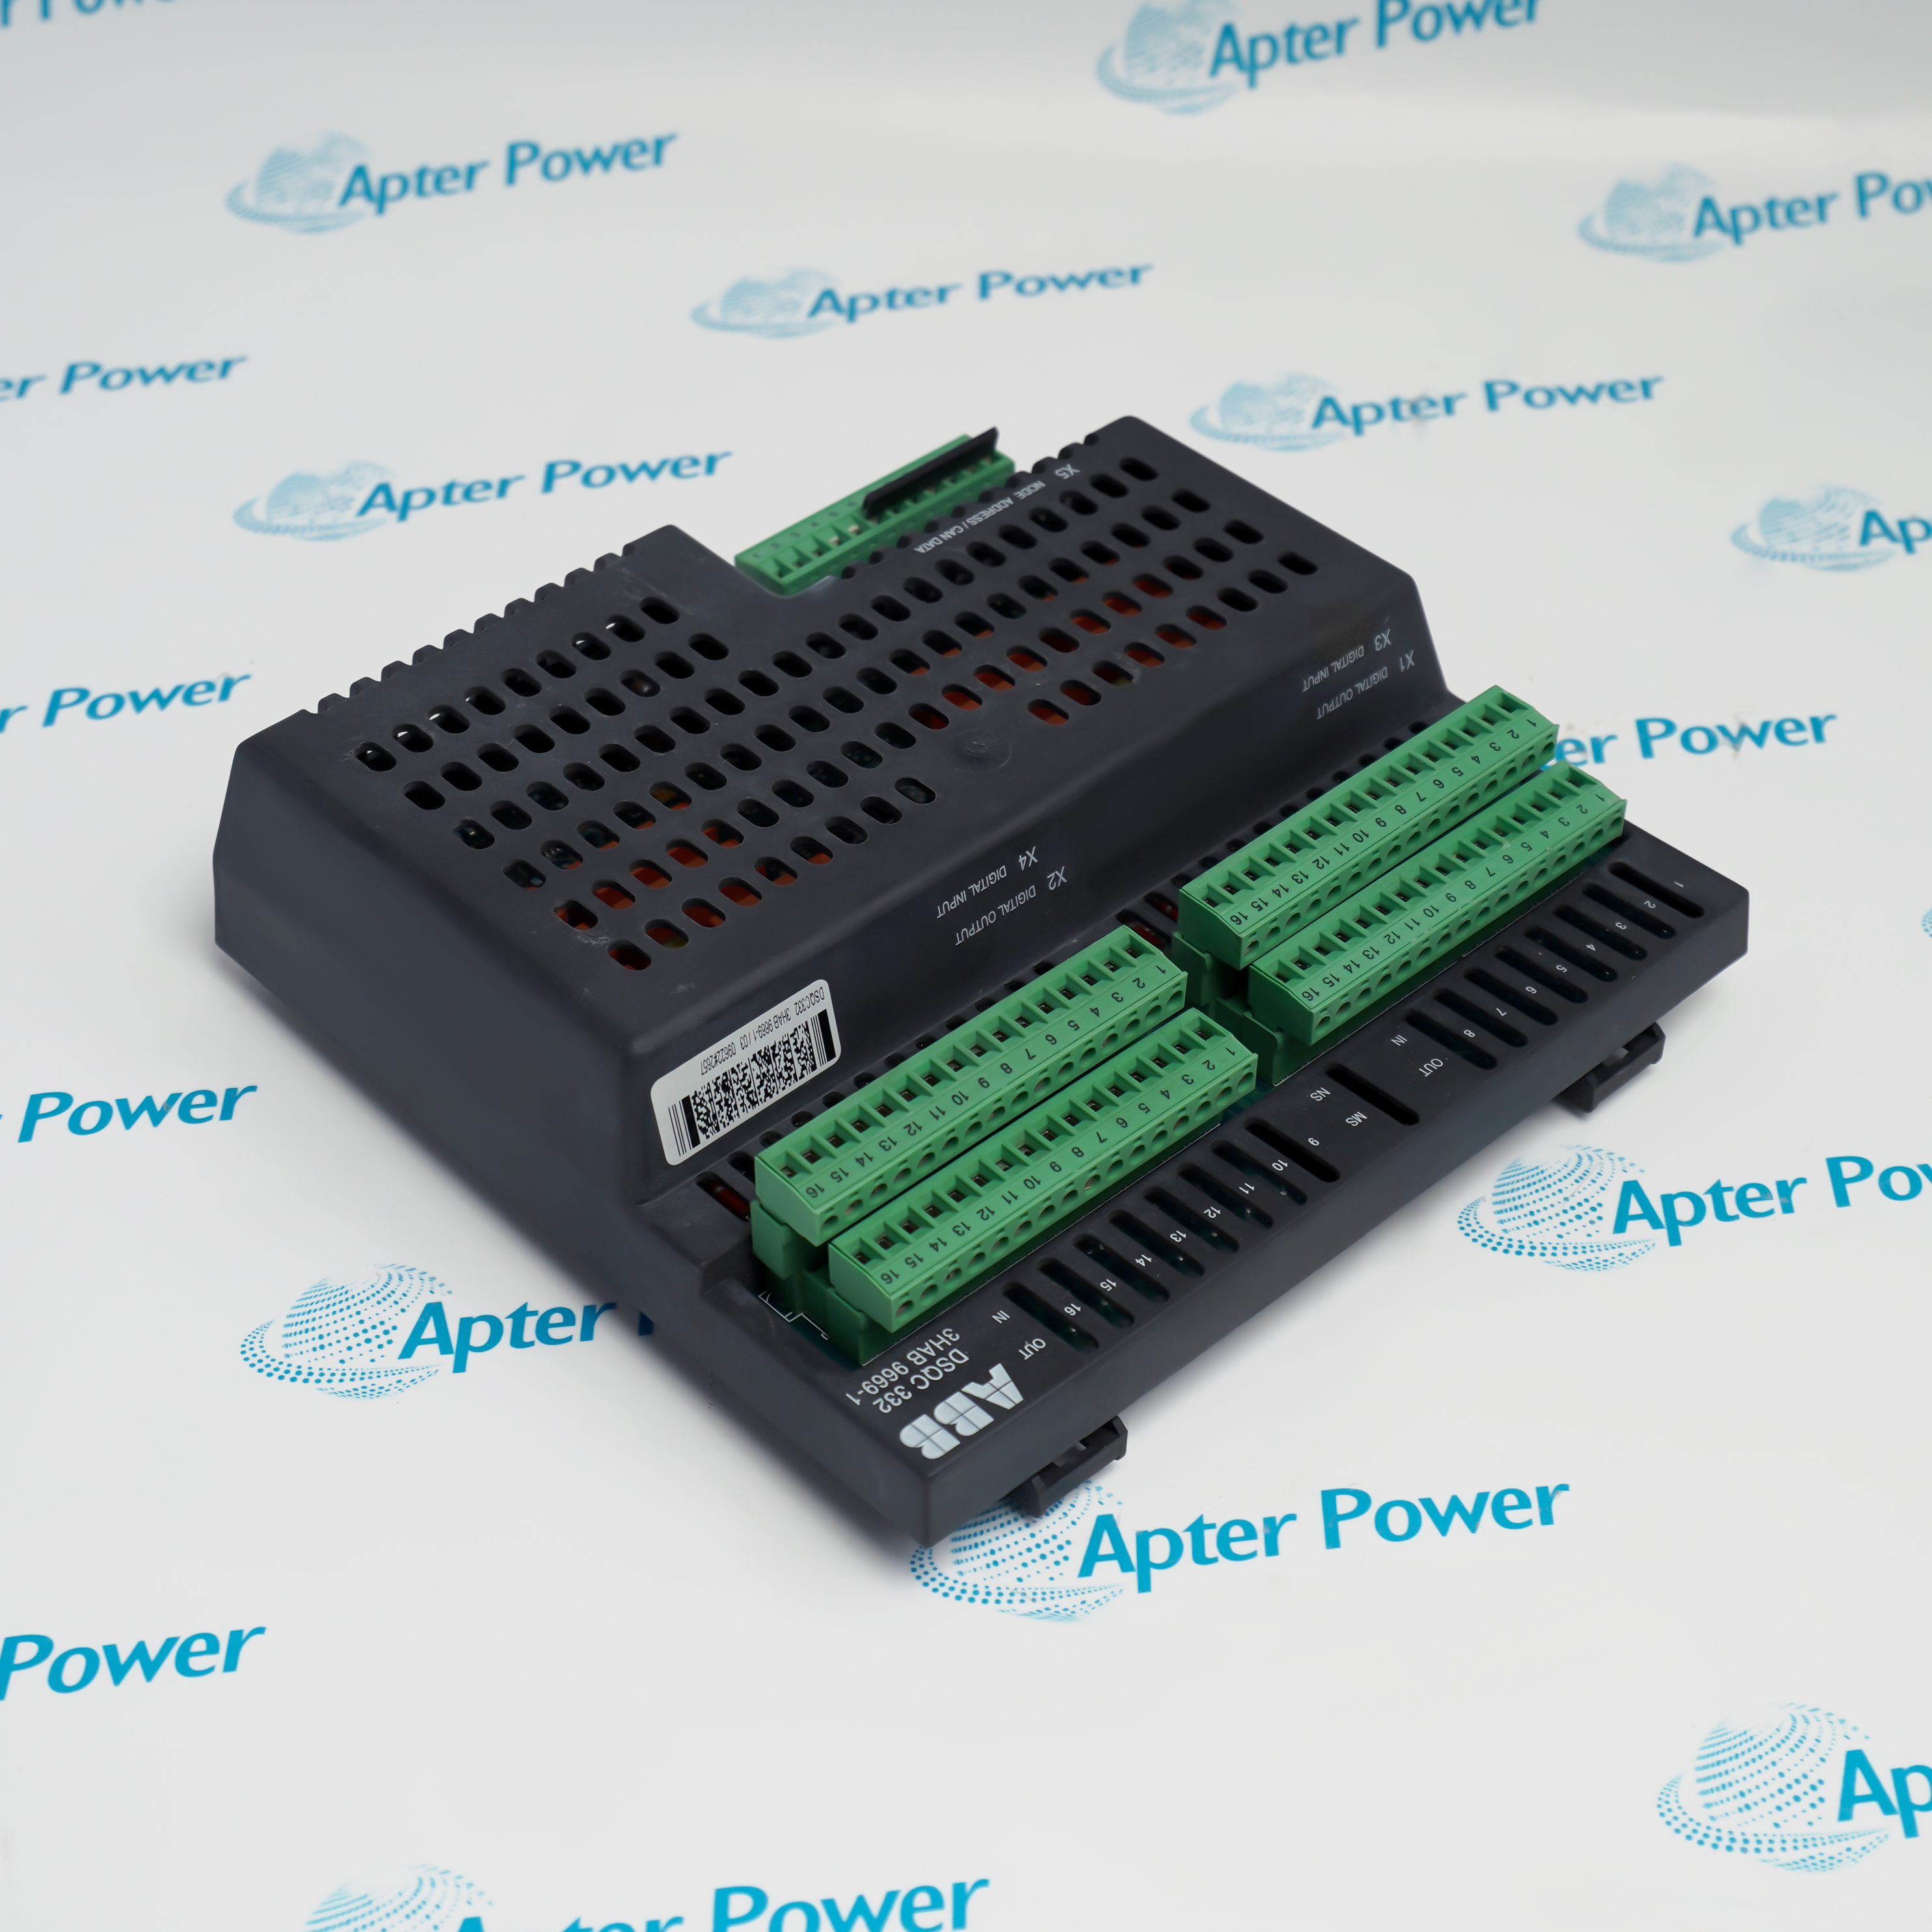
Verify the complete DSQC332 marking and its documented ABB S4Cplus M2000 robot controller position before field work.
Place the connected equipment in the approved maintenance state before removing DSQC332.
Isolate every applicable power, signal and stored-energy source, then prove a safe state at DSQC332.
Record the installed connectors, terminals, jumpers and channel or node assignments before disconnection.
Use ESD controls and protect keyed interfaces, edge connectors and exposed electronic assemblies.
Restore only the approved ABB S4Cplus M2000 robot controller hardware arrangement and configuration after replacement.
Energize DSQC332 in the documented sequence and review local, host and network diagnostics.
Prove the intended controlled function and retain the final acceptance record before production release.
Copyright Notice © 2026 apterpower.com All rights reserved,Apter Power is not an authorised distributor or representative of the manufacturers featured on this website. Brand names and trademarks featured are the property of their respective owners.